












 Dan’s Biz Bookshelf: ‘Building a Story Brand 2.0’
 It’s Only Common Sense: Why Should They Take Your Call?






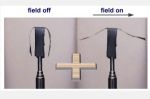
Researchers from North Carolina State University have developed a technique for using chains of magnetic nanoparticles to manipulate elastic polymers in three dimensions, which could be used to remotely control new "soft robots."
The ability to control the motion of soft robots, coupled with their flexibility, gives them potential applications ranging from biomedical technologies to manufacturing processes. Researchers are interested in using magnetic fields to control the movement of these soft robots because it can be done remotely - the control can be exerted without physically connecting to the polymer - and because magnetic fields are easily obtained from permanent magnets and electromagnets.
A team of researchers has now found a way of embedding long chains of nanoscale magnetite particles in sheets of elastic polymer to form a magnetic polymer nanocomposite. By applying a magnetic field, the researchers can control the way the nanocomposite bends - making it a soft robot.
The process begins by dispersing nanoparticles of magnetite - an iron oxide - into a solvent. A polymer is then dissolved into the mixture, which is poured into a mold to form the desired shape. A magnetic field is then applied, causing the magnetite nanoparticles to arrange themselves into parallel chains. The solution is dried, locking the chains into place, and the finished nanocomposite can be cut, to further refine its shape.
"Using this technique, we can create large nanocomposites, in many different shapes, which can be manipulated remotely," says Sumeet Mishra, a Ph.D. student at NC State and lead author of a paper on the work. "The nanoparticle chains give us an enhanced response, and by controlling the strength and direction of the magnetic field, you can control the extent and direction of the movements of soft robots."
The mechanism stems from the structure of the chains. The researchers have also constructed a simple model to explain how the chained nanoparticles affect the mechanical response in magnetic fields.
Page 1 of 2


